|
I'm a Master's student in the Erasmus Mundus Joint Master’s in Intelligent Field Robotic Systems at the University of Zagreb, Croatia, and previously at the Universitat de Girona, Spain. I earned my BS in Mechatronics at HUST with under Supervision Thoa Mac in the Intelligent Robotics lab. I have also been a Robotics Student Researcher in the VICOROB at University de Girona, and a Research Intern in the CLEAR LAB at National University of Singapore. I have also worked as a Robotics Researcher at the Industry Grade Networks and Clouds lab at TU Berlin. I also workes as a R&D Engineer at Hyundai Kefico Vietnam in Vietnam. |
|
|
Dec 2025I joined the VICOROB Lab as a Robotics Student Researcher under the supervision of Narcís Palomeras. 🚀 Oct 2025Our paper "Arena-Bench 2.0: A Comprehensive Benchmark of Social Navigation Approaches in Collaborative Environments", based on my bachelor's thesis, has been accepted to IROS 2025. 🎉 Sep 2025I began my graduate studies in the Erasmus Mundus Joint Master's in Intelligent Field Robotic Systems. ✨ Jun 2025I joined the CLEAR Lab as a Robotics Student Researcher Intern. 🤖 May 2025Our paper "Human-Aware Robot Navigation Using Modified Social Force Model" has been accepted to the Arabian Journal for Science and Engineering. 🎉 Apr 2025Our paper "Demonstrating Arena 5.0: A Photorealistic ROS2 Simulation Framework for Developing and Benchmarking Social Navigation" has been accepted to RSS 2025. 🎉 Feb 2025Our paper "Arena 4.0: A Comprehensive ROS2 Development and Benchmarking Platform for Human-centric Navigation Using Generative-Model-based Environment Generation" has been accepted to ICRA 2025. 🎉 Apr 2024I joined the Industry Grade Networks and Clouds Lab as a Robotics Student Researcher Intern. 🤖 |
|
I am driven by a passion for robot control and machine learning, with a particular interest in enabling robots to operate robustly and generalize in dynamic, real-world environments. My research focuses on developing algorithms and systems that combine learning from experience with control theory, allowing robots to adapt to new situations and make intelligent decisions in complex, uncertain environments. In particular, I explore how machine learning techniques can be integrated with control theory to enhance the capabilities of robotic systems, enabling them to learn from data and improve their performance over time. My goal is to bridge the gap between theoretical advances and practical applications, contributing to intelligent robotic systems that operate reliably in real-world scenarios. |
|
|
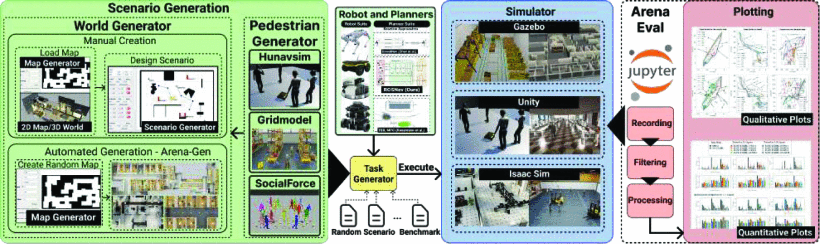 |
Volodymyr Shcherbyna, Linh Kästner, Duc Anh Do, Jiaming Wang, Huu Giang Nguyen, Tim Seeger, Ahmed Martban, Zhengcheng Shen, Huajian Zeng, Nhan Trinh, Eva Wiese IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2025 Arena-Bench 2.0 a comprehensive social navigation benchmark of state-of-the-art planners, fully integrated into the Arena framework. Paper |
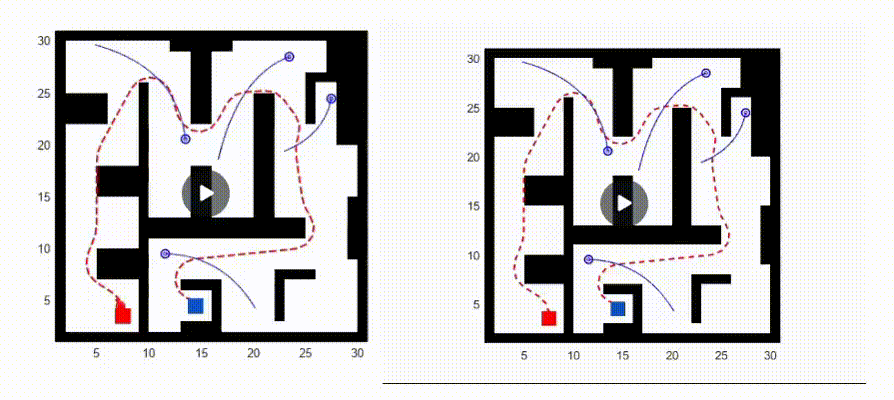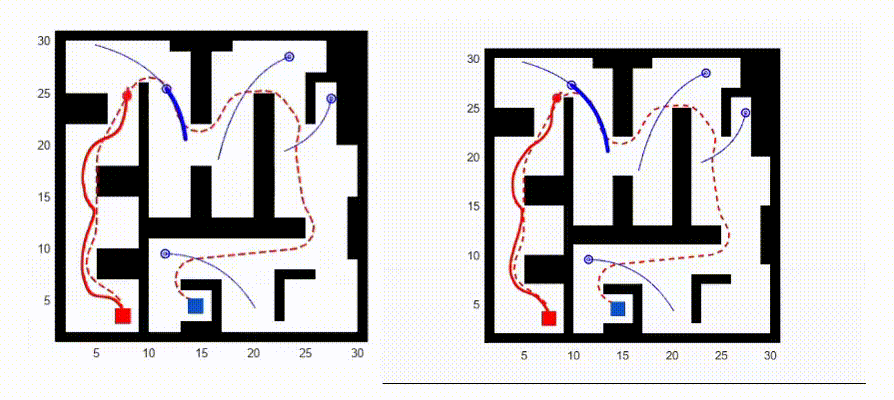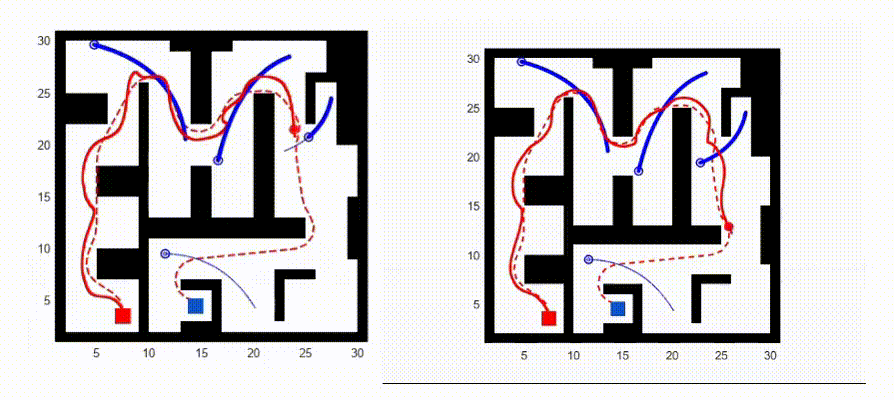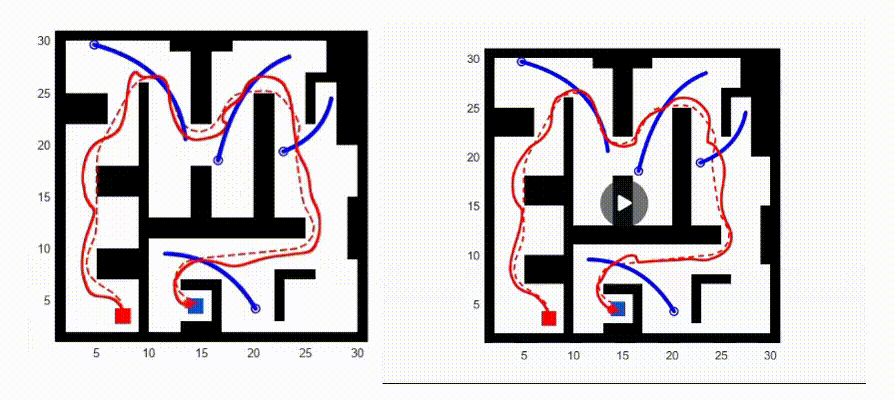 |
Thi-Thoa Mac, Huu-Truong-Giang-Nguyen, Hoang-Hiep Ly, Xuan-Thuan Nguyen Arabian Journal for Science and Engineering, 2026 Extend the social force model to better capture human behavior in robot navigation scenarios. arXiv |
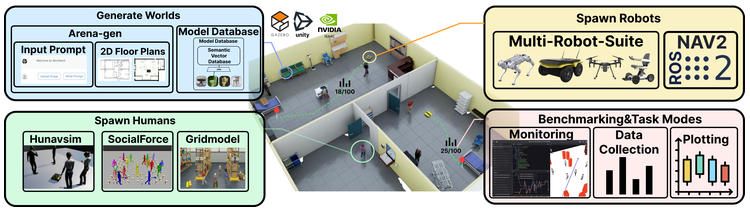 |
Linh Kästner, Volodymyr Shcherbyna, Harold Soh, Giang Nguyen Huu Truong, Do Duc Anh, Ton Manh Kien, Tim Seeger, Ahmed Martban, Vu Thanh Lam, Nguyen Quoc Hung, Pham Thai Hoang Tung, Tran Dang An, Eva Wiese, Maximilian Ho-Kyoung Schreff Robotics: Science and Systems (RSS), 2025 Advancing the Arena platform further, Arena 5.0 delivers a next-generation simulation and benchmarking infrastructure for social navigation, combining photorealism, complete ISAC SIM Integration, ROS 2 support, and flexible scenario creation. arXiv / Website |
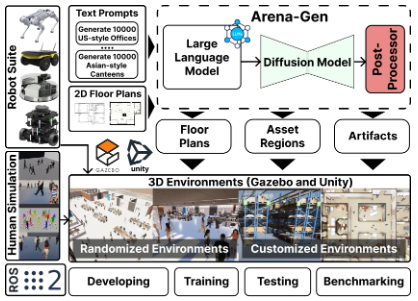 |
Volodymyr Shcherbyna, Linh Kastner, Diego Diaz, Huu Giang Nguyen, Maximilian Ho–Kyoung Schreff, Tim Seeger, Jonas Kreutz, Ahmed Martban, Zhengcheng Shen, Huajian Zeng, Harold Soh International Conference on Robotics and Automation (ICRA), 2025 A comprehensive ros2 development and benchmarking platform for human-centric navigation using generative-model-based environment generation. arXiv |
| Template inspired by Jon Barron. |